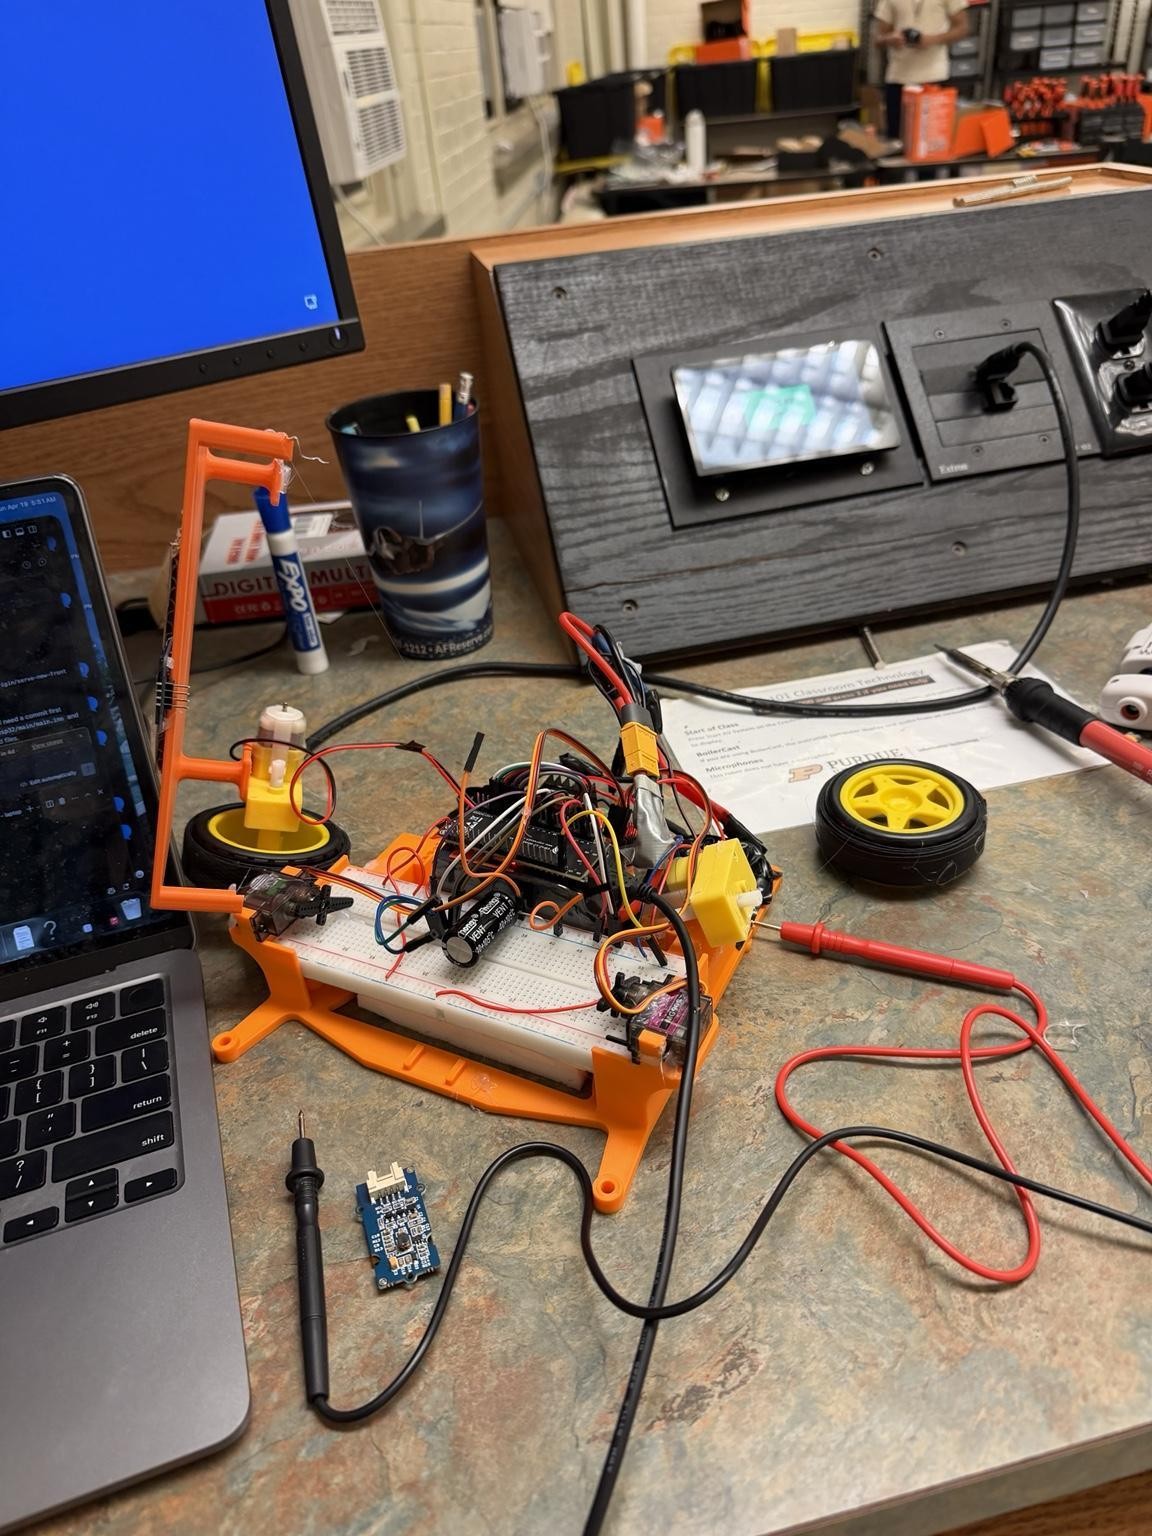
MagClean 2.0
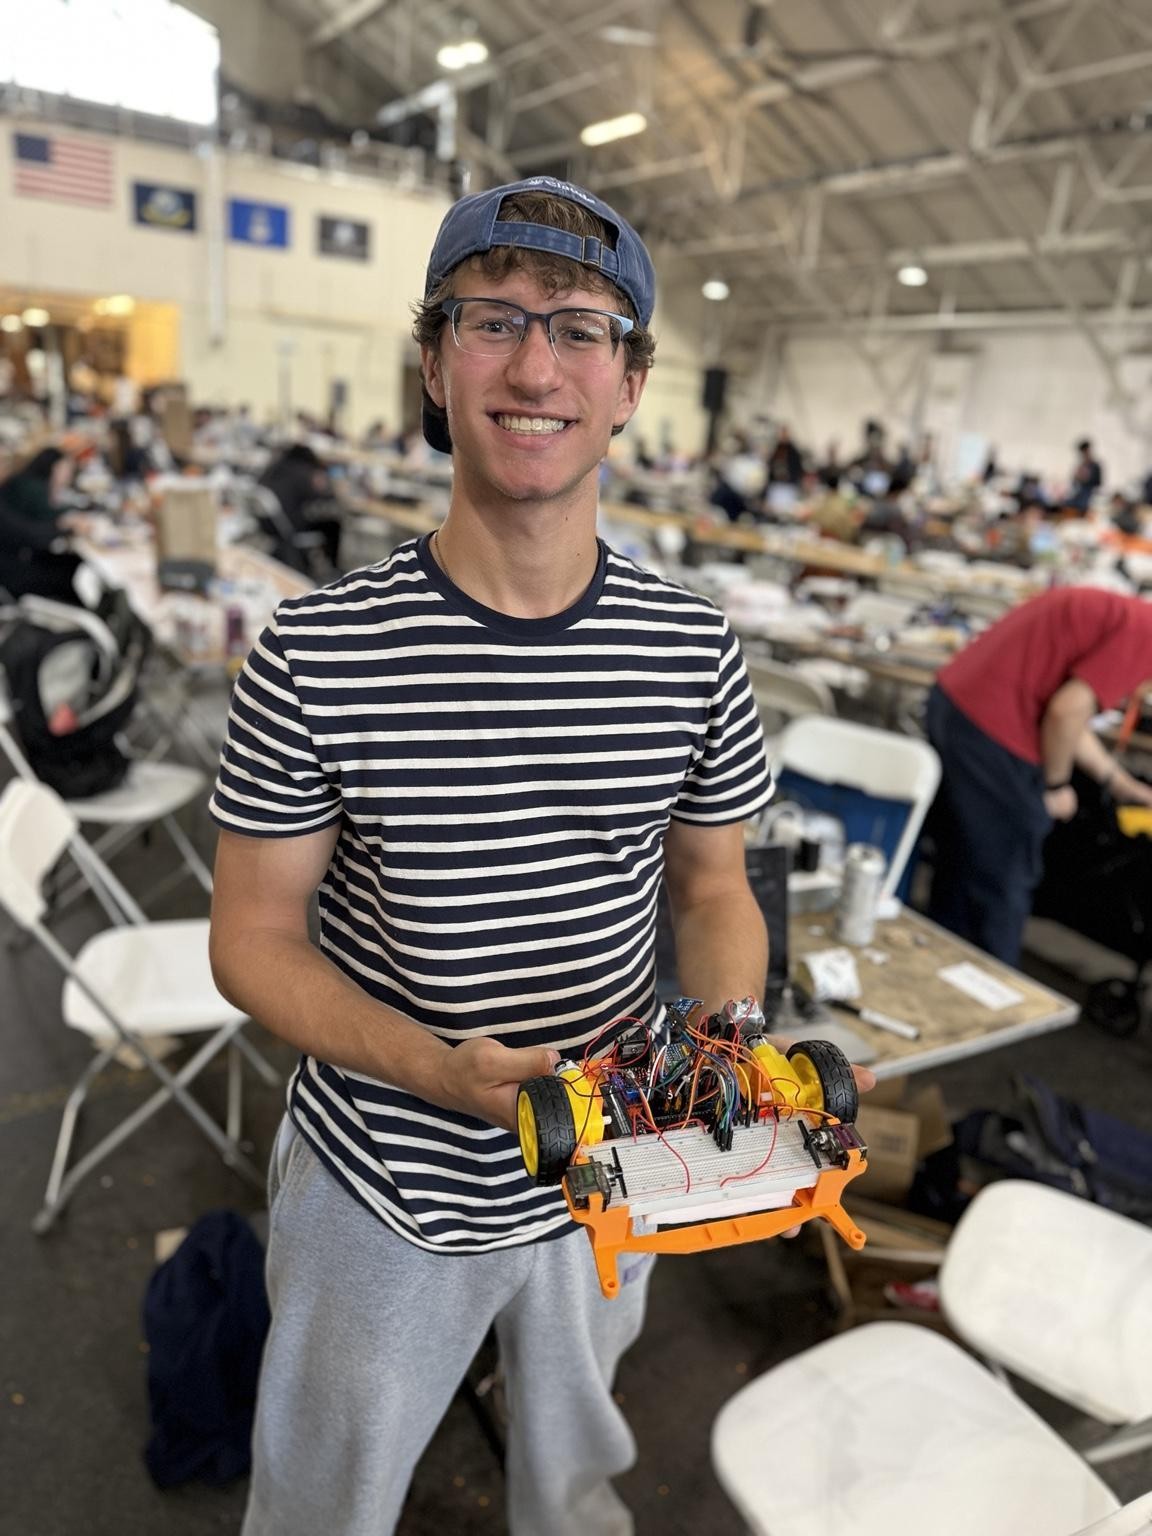
A magnetic whiteboard-cleaning robot built in 36 hours at StarkHacks in April 2026.
Mechanical and Electrical Build
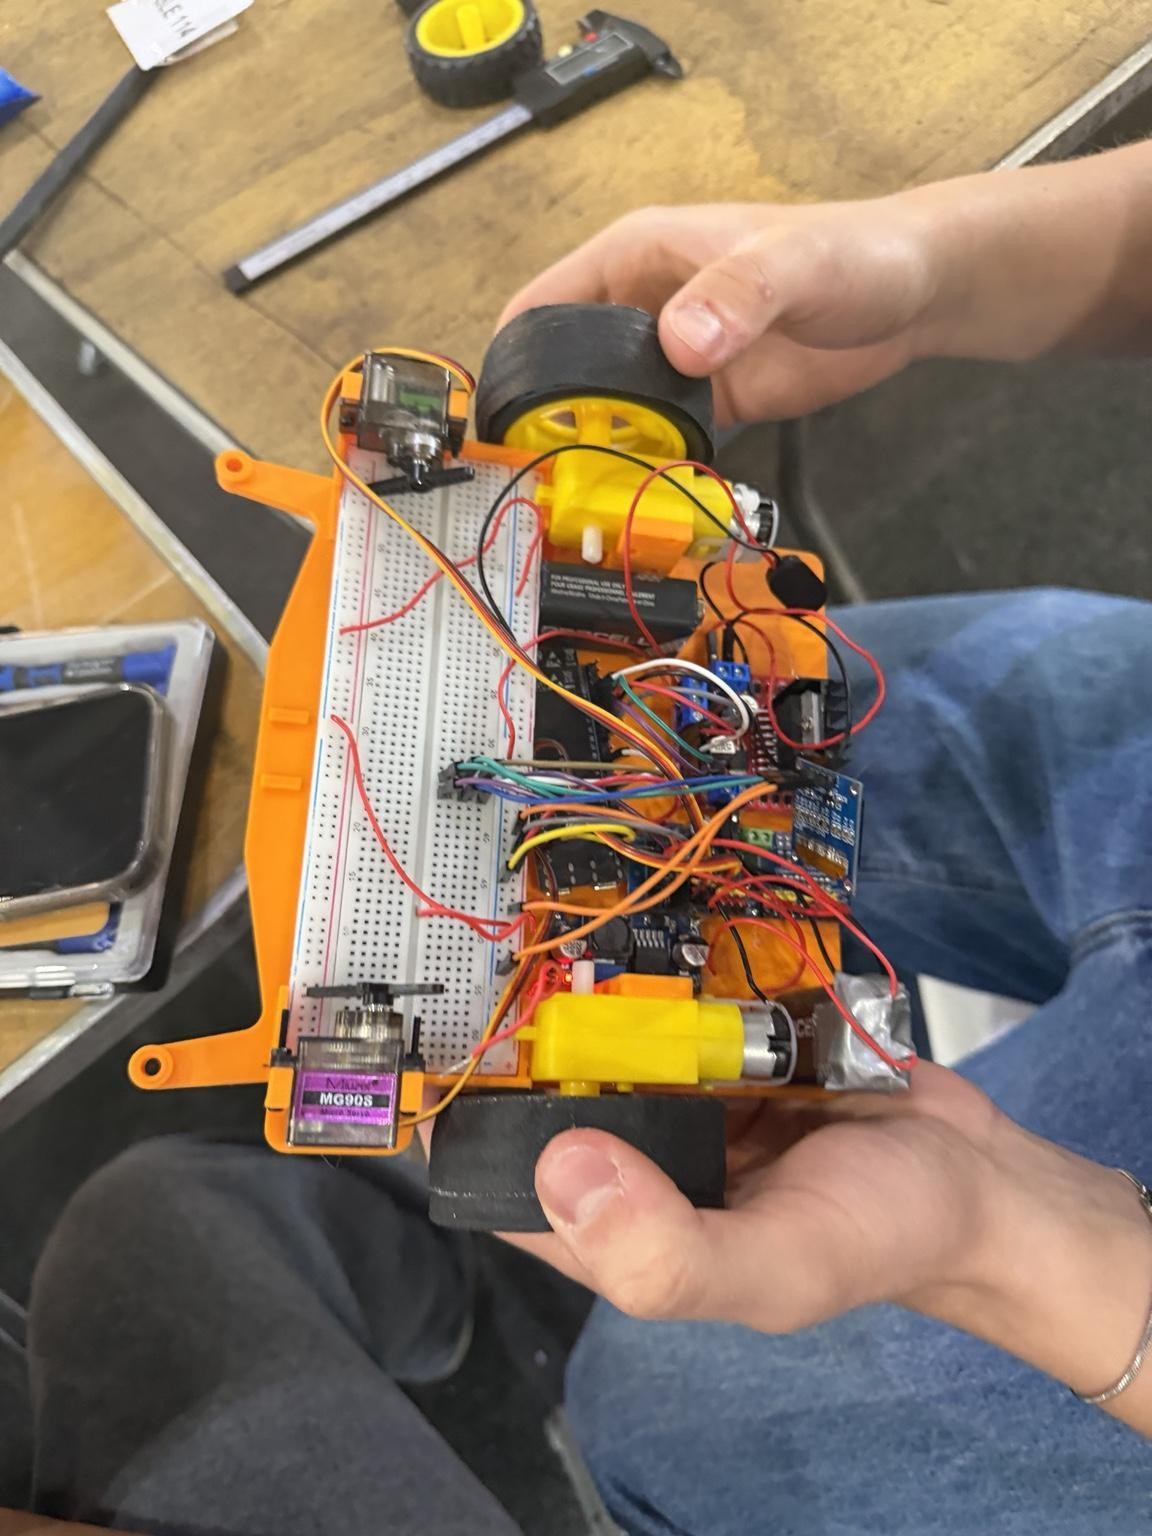
I handled most of the physical build, including CAD, 3D-printed parts, wiring and soldering, ESP32 motor control, and ToF sensing. The design balances magnetic adhesion, weight, traction, and motor authority.
Localization and Cleaning
An external camera provides ArUco localization and dirty-zone detection. By the end of the hackathon, the robot stayed on the board, planned a path, and ran cleaning motions autonomously.