OpenArm / HAND-ERC
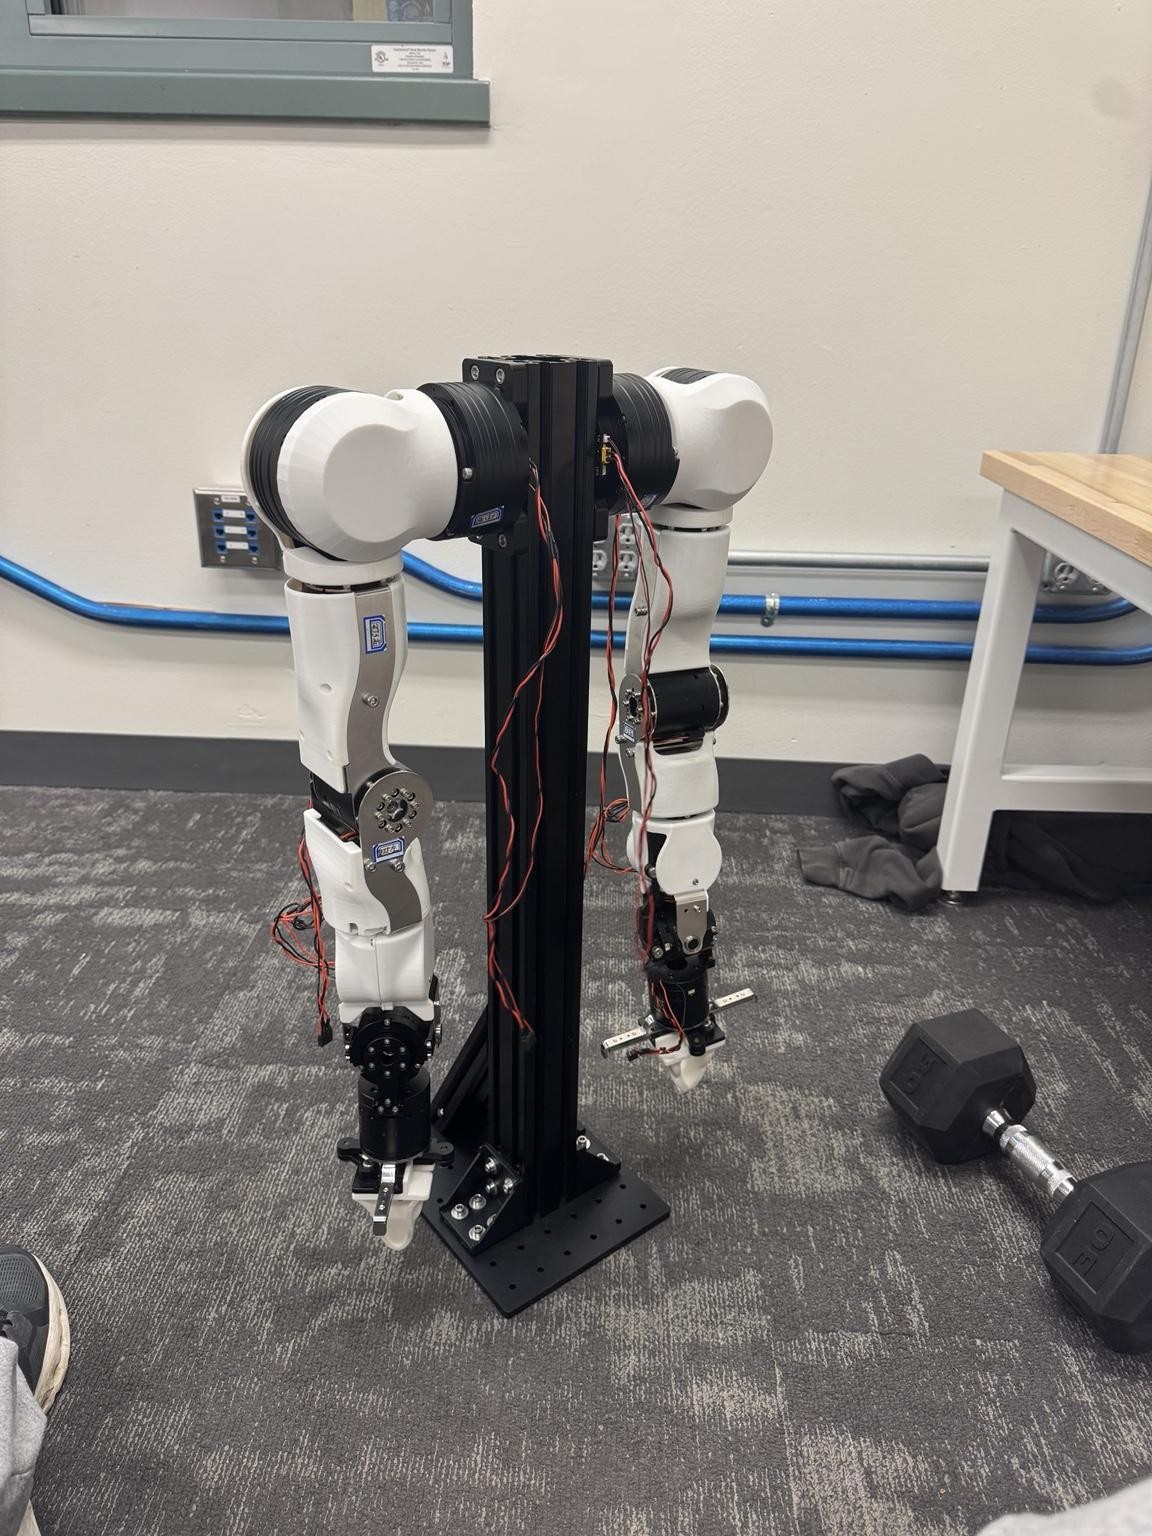
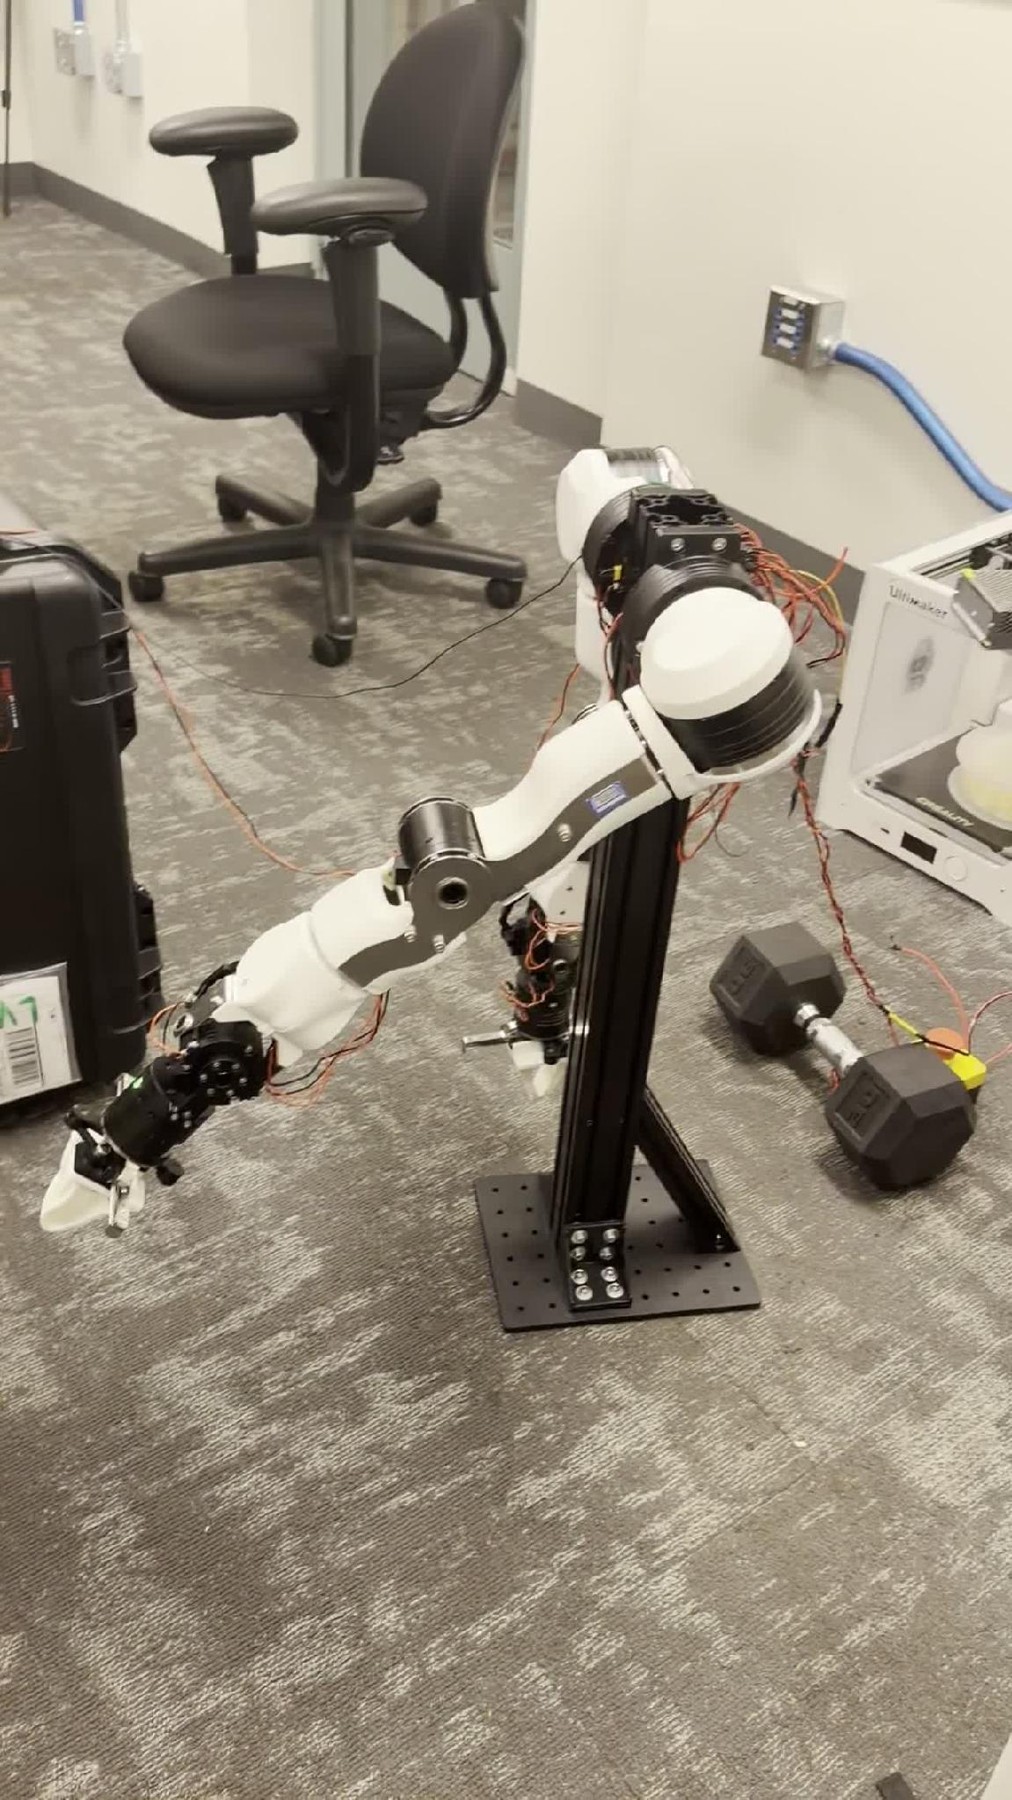
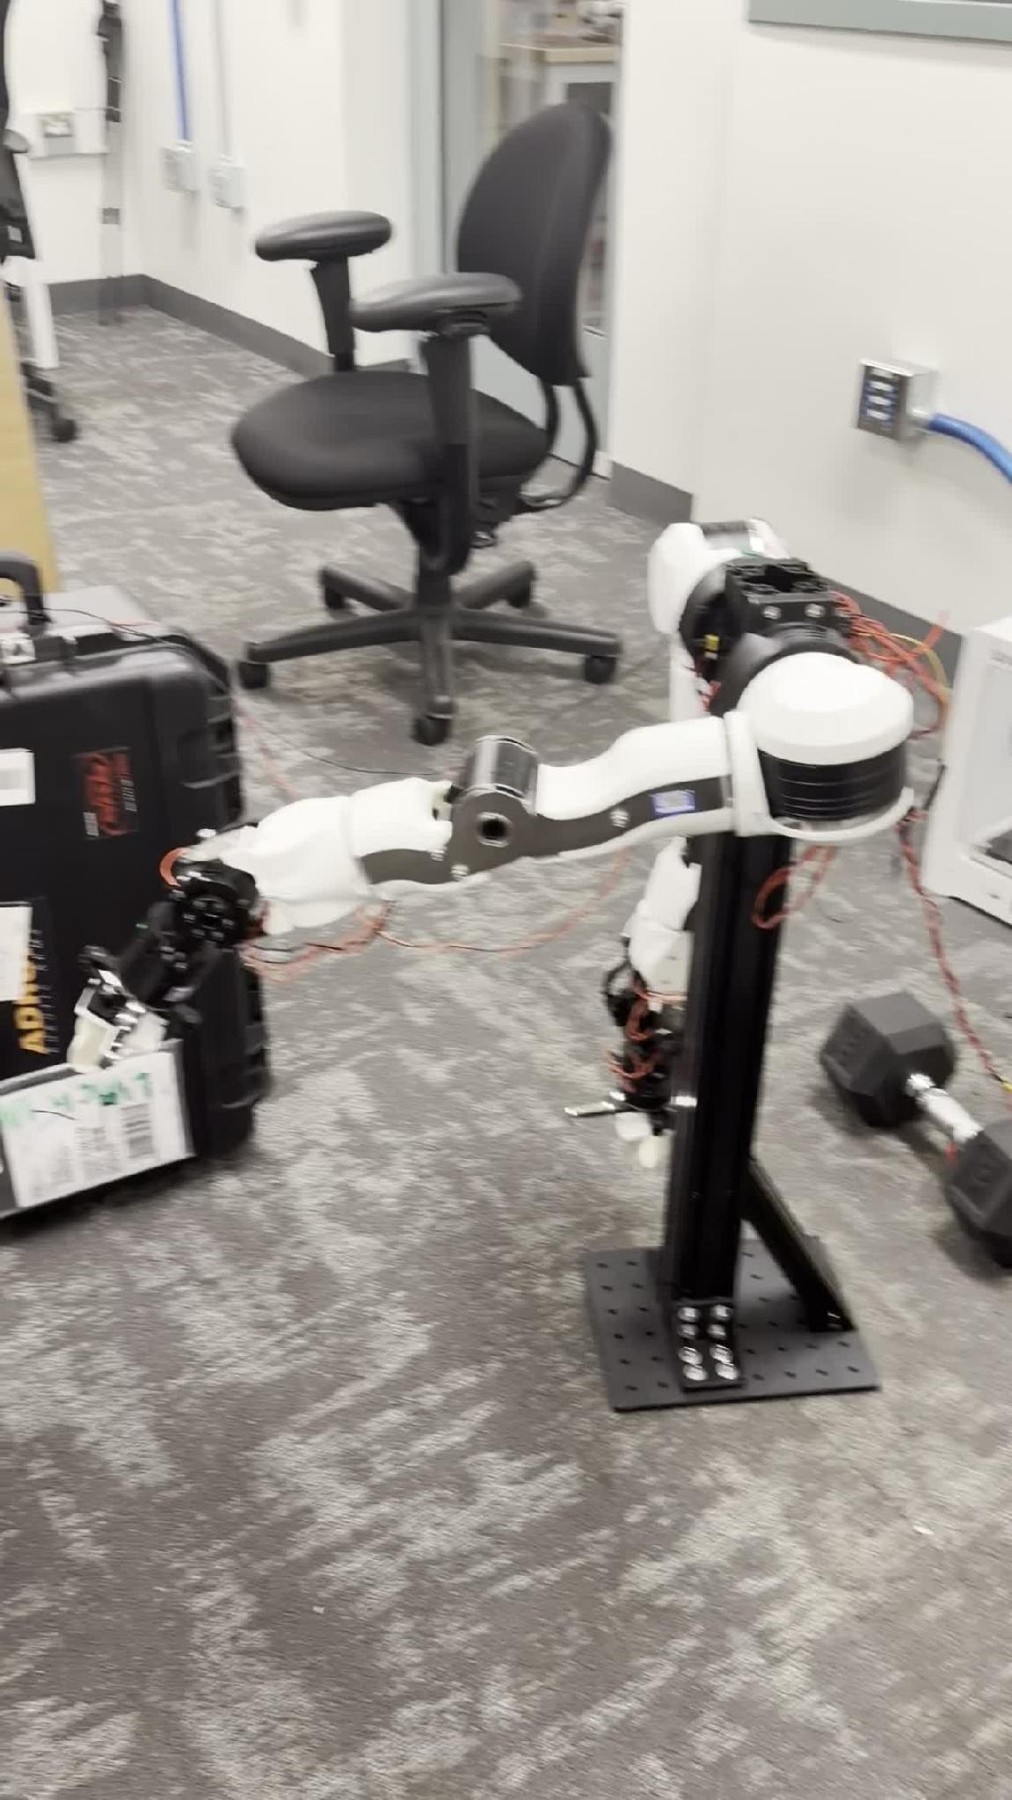
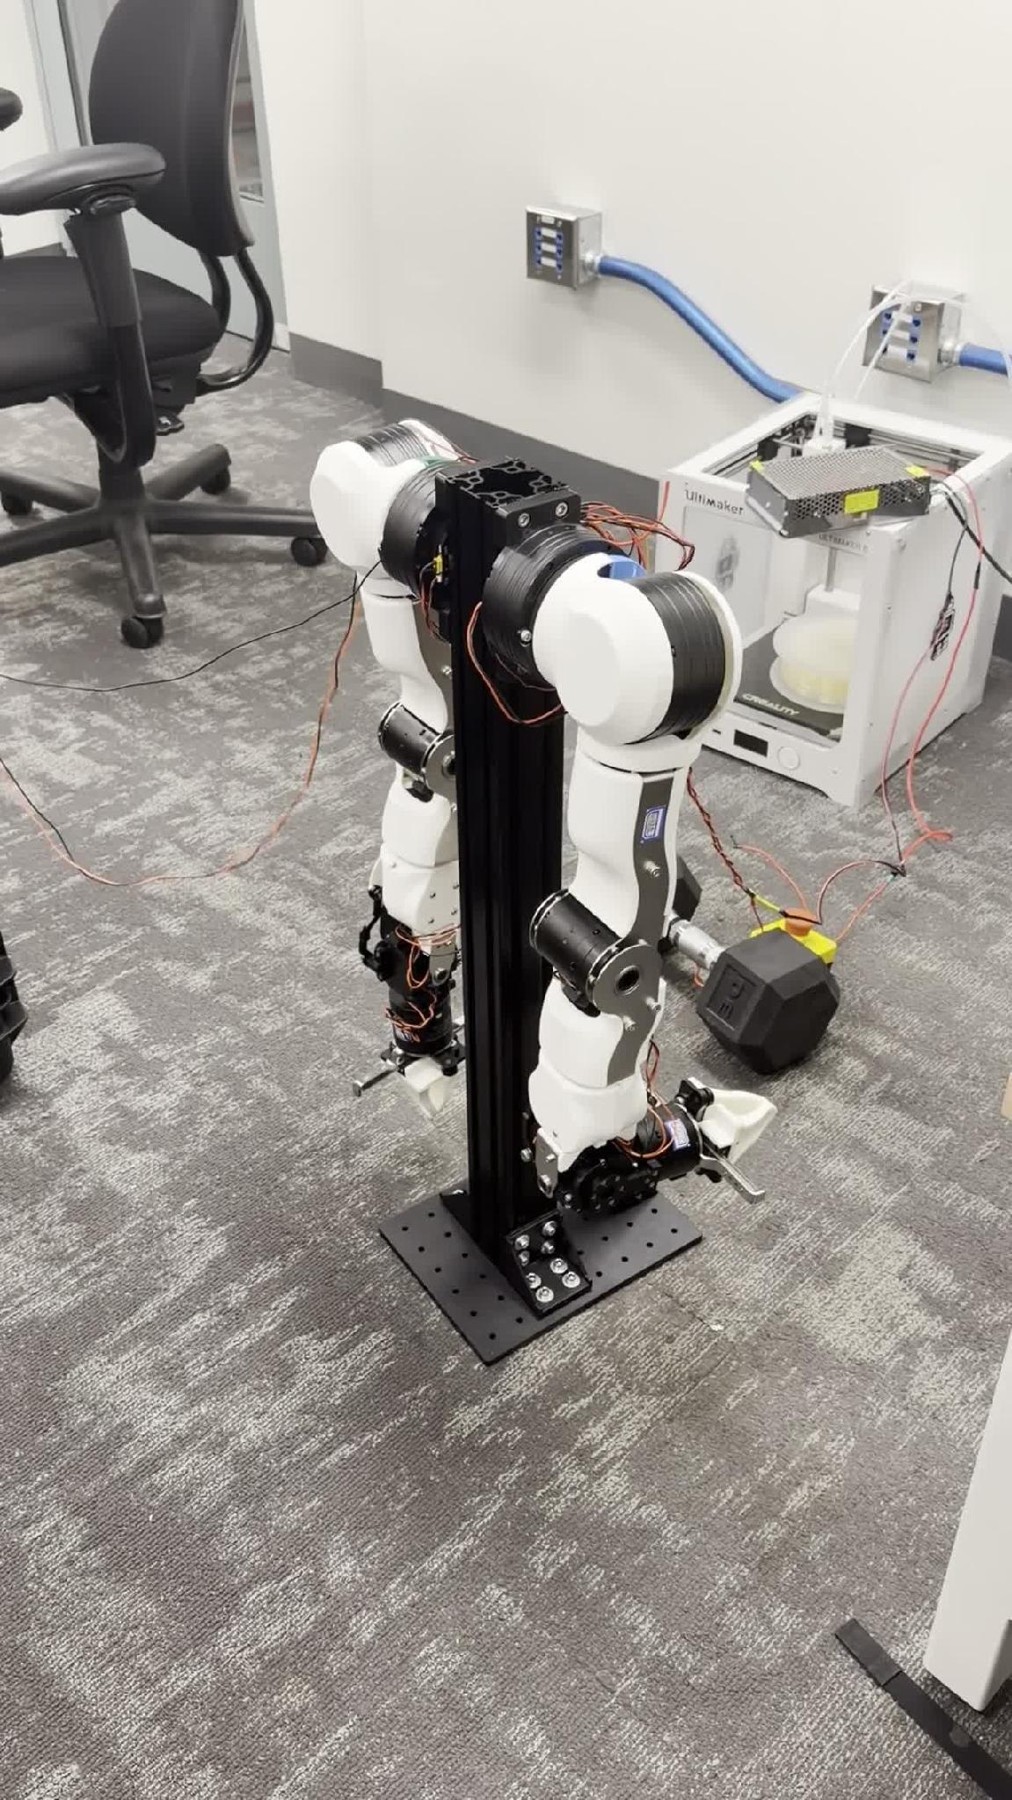
I assembled and wired two research robot arms and worked on CAN motor communication, ROS 2 trajectory execution, MoveIt planning, and joint calibration.
Hardware Debugging
When motor feedback failed, I inspected raw adapter output and ruled out wiring and motor setup. Replacing a faulty CAN adapter restored feedback. I also added an explicit mapping between CAN IDs and physical joints so commands reached the intended motors.
Physical Motion
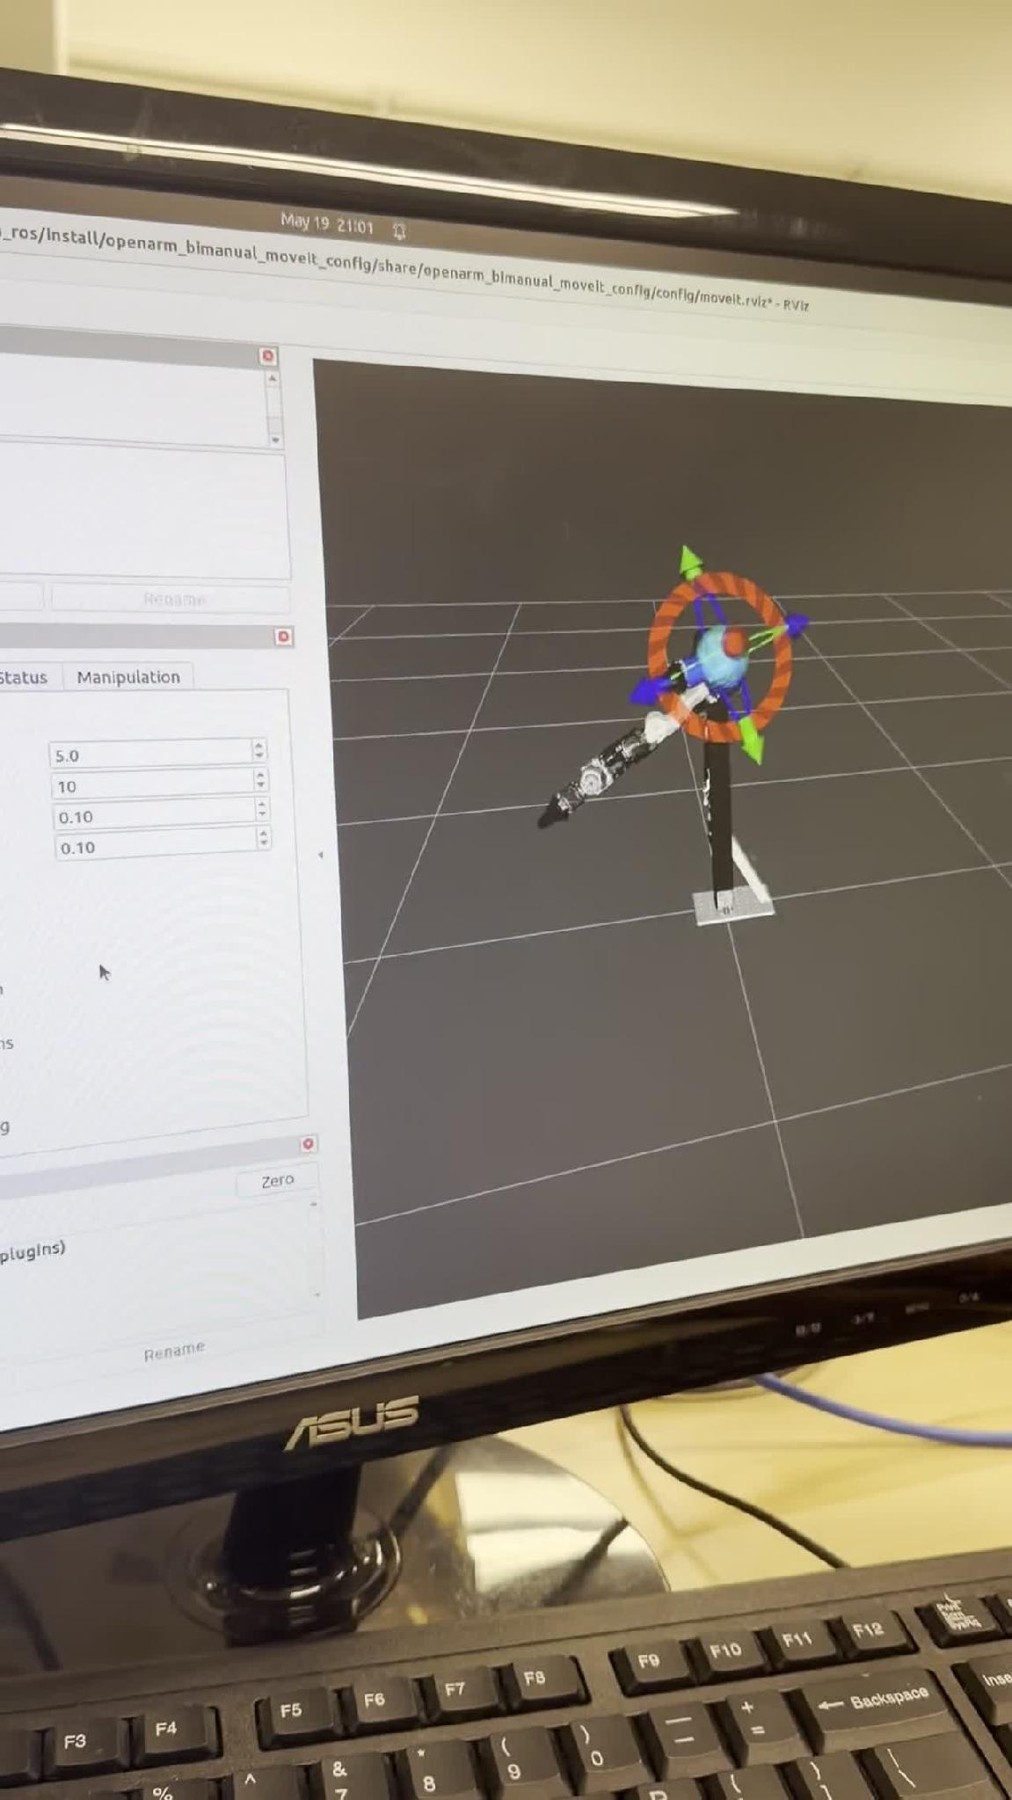
MoveIt-planned motion runs on physical robot hardware. These frames show a commanded movement.